We built EmbodyX because scripted robots keep stopping the line
EmbodyX, Inc. was founded in San Jose in 2024 by engineers who spent years watching scripted robot programs fail in production. We built the platform we wish had existed when we were the ones calling engineers at 6am to re-teach arms.
Make industrial robot arms as adaptive as the workers they work alongside
A factory floor worker handles variation naturally. A bolt lands at an odd angle, they adjust their grip. A bin refills with a slightly different part, they recognize it and pick it anyway. A task description changes before the shift, they understand the goal and figure out the motion.
Industrial robot arms, programmed the traditional way, do none of this. They follow coordinates. When the world doesn't match the program, they stop. Every stop costs time, and every re-teach costs engineering hours that facilities cannot always spare.
Our mission is to close that gap with software. Vision-language-action models give arms the ability to perceive, reason, and act in real conditions. We build the inference stack that makes that practical on the arms that are already on production lines today.
The people who built it
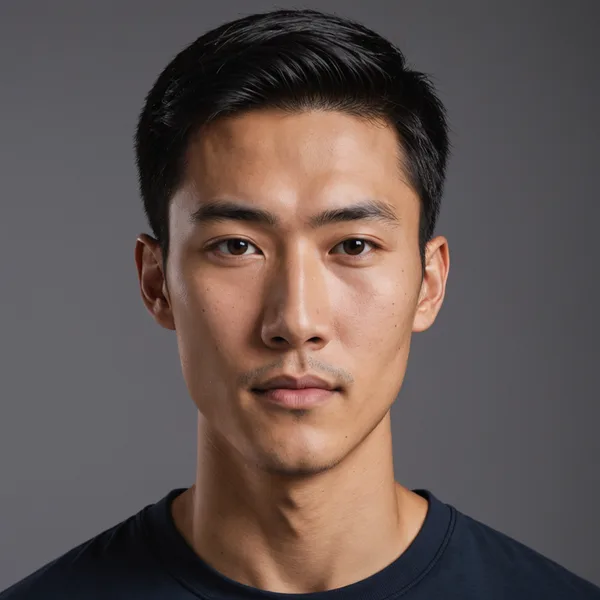
Background in industrial perception systems, building the vision stack that runs on production factory floors. Saw the same re-teach failure pattern repeat at every customer site and co-founded EmbodyX to address it at the model level rather than patching it at the controller level.
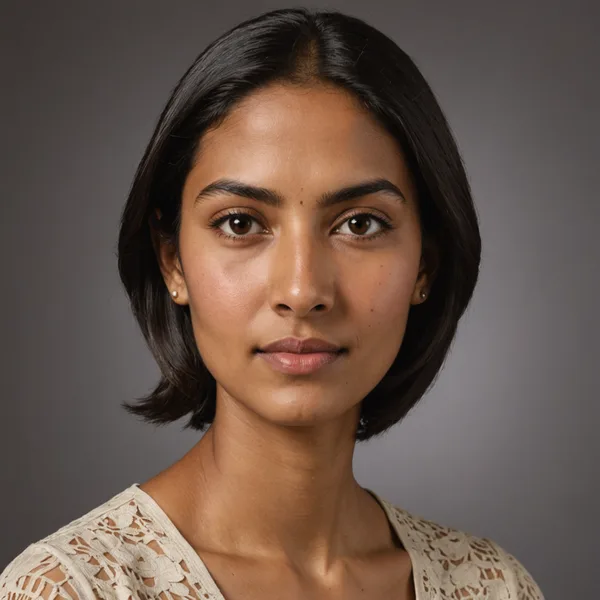
Worked on ML inference systems inside high-throughput logistics operations, building the stack that handles mixed-SKU sortation where throughput and cycle time aren't negotiable. Her focus at EmbodyX is getting the VLA model compact and fast enough to run at the arm's own control frequency with no cloud dependency.
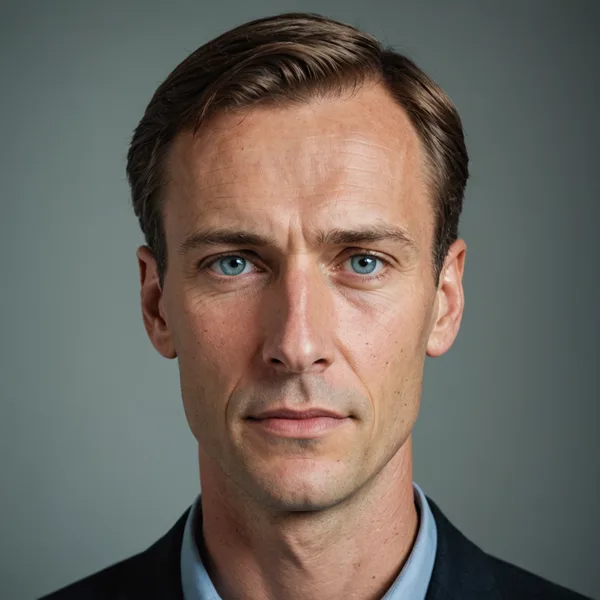
Spent his career commissioning and deploying robot arms across automotive and industrial manufacturing facilities. Lars owns the OEM SDK integration layer at EmbodyX, making sure every new arm adapter works on the floor, not just in a lab.
Why we started in 2024
The idea for EmbodyX came out of a specific frustration: watching a well-engineered scripted system fail on a Monday morning because a supplier had changed their part packaging over the weekend. The arm expected a part at a specific XYZ coordinate. The part was 4mm off. Line stop. Engineer called in. Two hours to re-teach. $12,000 in lost production time.
That failure mode is not a configuration error. It is the fundamental constraint of scripted automation. The program describes a fixed world. The world is not fixed.
By 2024, the foundation model research had reached the point where a small, quantized vision-language-action model could run on edge hardware at real-time arm control frequencies. That was the missing piece. Chen and Priya started EmbodyX to build the production-grade inference stack that bridges foundation model capability and real industrial arm deployment.
The company is bootstrapped. We take our time getting the engineering right before scaling deployment. Every new OEM integration goes through Lars's commissioning process before it ships to customers.
Work with the team directly
Every evaluation pilot starts with a call with Lars's integration team. Tell us your arm, your task, and the specific failure you want to fix. We will design the evaluation around that.