Robots that read the scene. Then act.
EmbodyX deploys VLA model inference on industrial robot arms so they handle unscripted tasks without reprogramming. Manufacturing and logistics, out of the box.
How VLA inference works
Three steps from raw scene to executed motion, all on your local network.
Perceive
Cameras and depth sensors capture the scene in real time. EmbodyX builds a spatial scene graph from every object in the workspace.
Reason
The VLA model processes the scene graph against your natural-language task instruction and outputs a grounded action plan for the robot arm.
Act
Joint trajectories are sent directly to your robot arm controller. EmbodyX supports UR, KUKA, and Fanuc out of the box with no custom code.
Where it deploys
EmbodyX targets the two highest-value unscripted manipulation environments in industry.
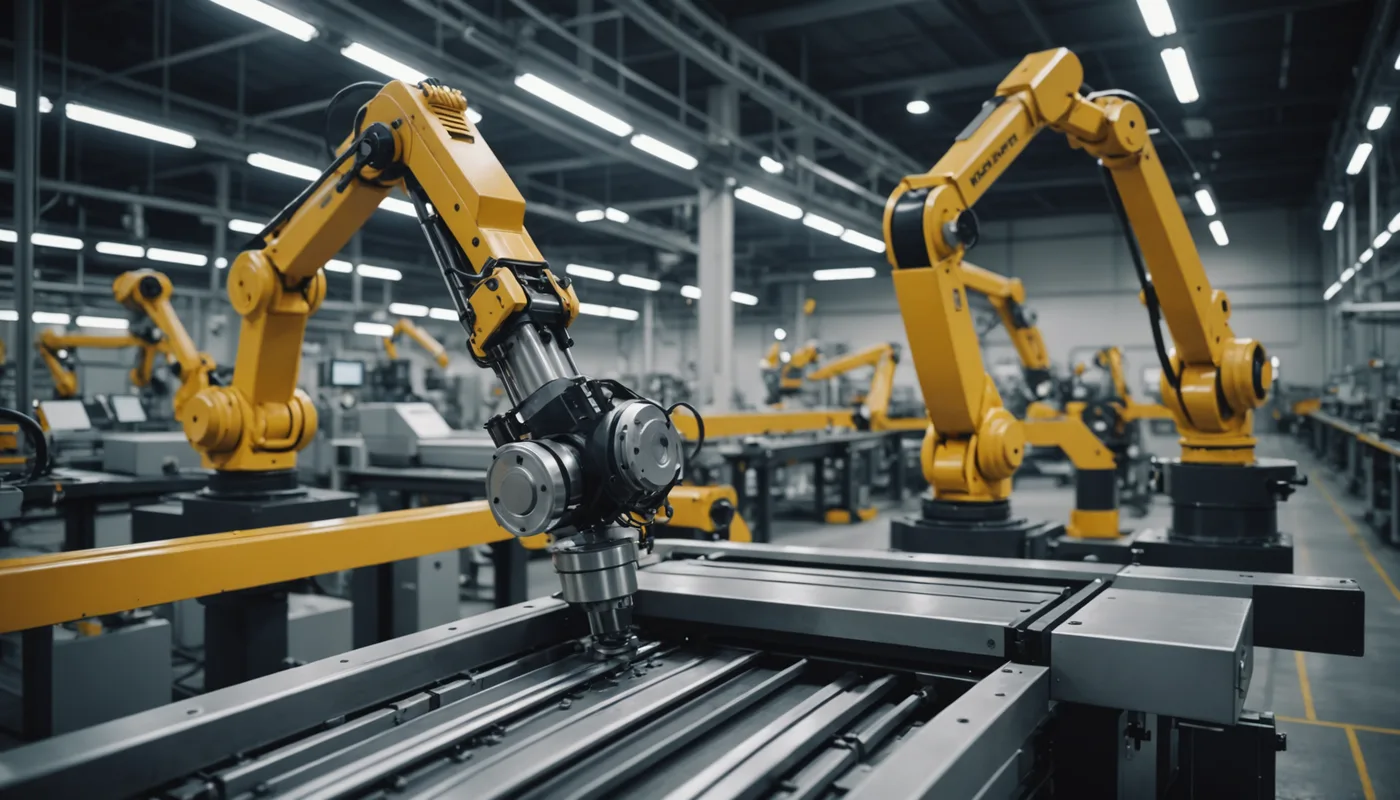
Assembly line bin-picking and placement
Factory lines with varied part geometries and mixed SKUs stop production when robots encounter an unrecognized configuration. EmbodyX reads the scene and continues without intervention.
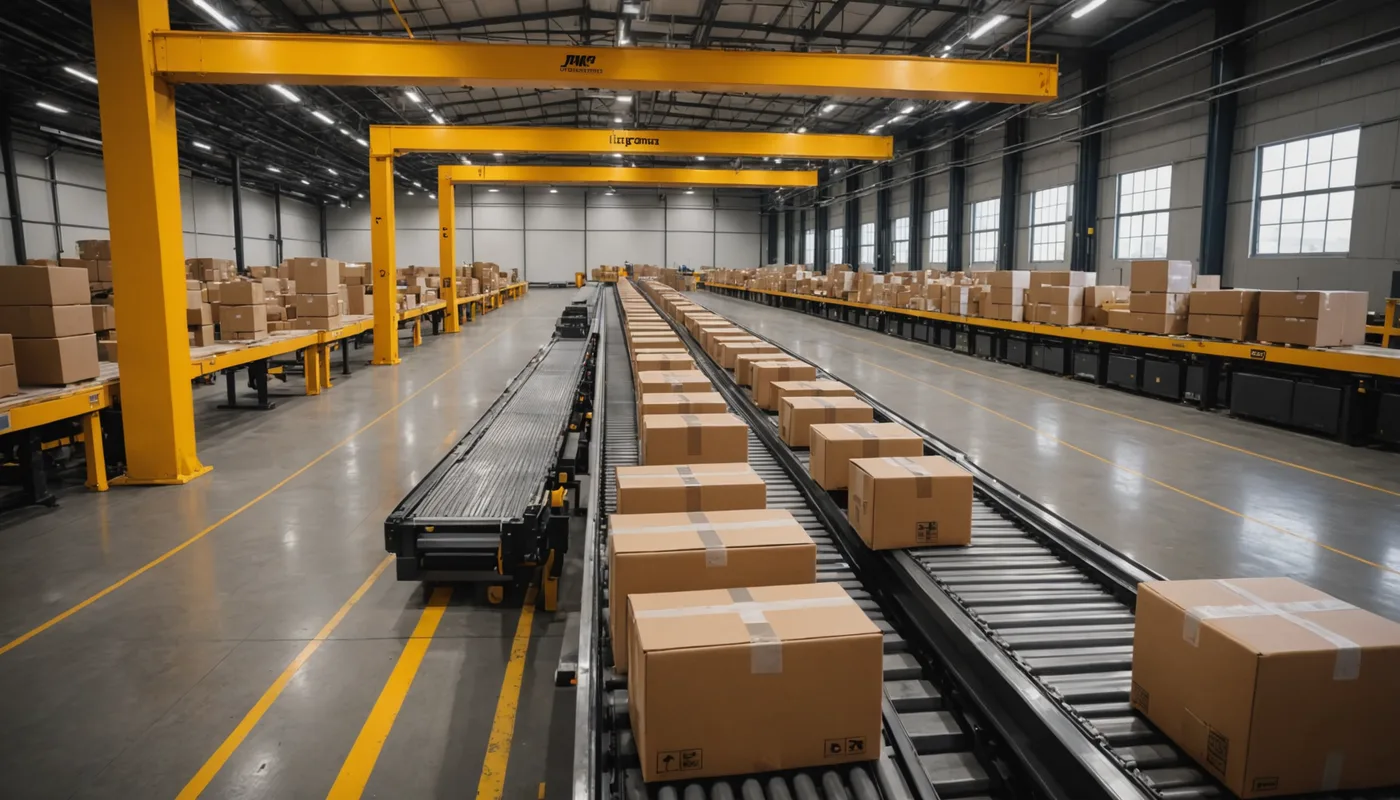
Mixed-SKU warehouse sortation
Fulfillment centers with high mix inbound flows can't pre-program every box shape. EmbodyX enables arms to identify, grasp, and route any package without a library of object models.
We ran a 30-day pilot on two UR10e lines. Scrap from part-handling errors dropped noticeably and we hit 97% first-attempt success on a mix we had never seen before. The integration team had us running in three hours, not three weeks.
Automation Lead, Tier-1 automotive supplier, early-access pilot programBuilt by robotics engineers
The EmbodyX founding team brings together backgrounds in perception systems, deep learning, and industrial automation integration.
Built perception systems for industrial automation, tracking how the gap between scripted robot capabilities and real factory conditions compounds across every product cycle. Co-founded EmbodyX to close that gap.
Background building ML inference systems for high-throughput logistics, working on the parts of the stack that have to keep up with conveyor speed and arm cycle time. At EmbodyX, focused on getting VLA inference under the latency ceiling that production arms require.
Career in robotics integration: commissioning FANUC, KUKA, and UR arms across automotive and industrial manufacturing facilities. Knows the failure patterns of scripted automation at first hand, and what each hour of line stop costs.
Put a VLA model on your production line
Start with a 30-day free evaluation on one arm in your facility. No integration contract required.